
Safe and Resilient Multi-Agent Cooperation: From Fault Detection to Safety Assurance
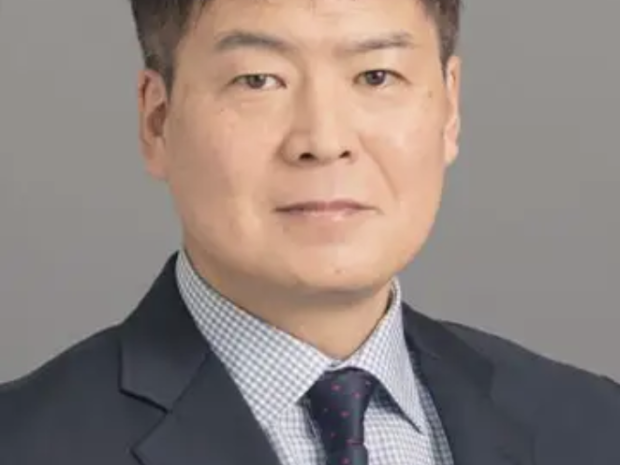
Speaker
Toru Namerikawa
Professor in the Department of System Design Engineering and the Director of the School of Integrated Design Engineering, Graduate School of Science and Technology at Keio University
Abstract
Cooperative autonomous systems must maintain safe operation even when individual agents fail. Fault detection and reconfiguration can restore coordination after a failure is identified, but what happens when a fault remains below the detection threshold? This seminar addresses this question through our recent work on resilient multi-agent cooperation, with multi-UAV formation control as an experimental testbed.
We first review our development of distributed fault detection, trust-based formation control, and leader replacement, supported by flight experiments. These methods enable a team to reorganize following a detected agent failure. However, undetected actuator degradation can compromise collision avoidance while leaving the formation controller unaware of the fault. It also undermines the premise of common multi-agent safety certificates, which assume that each agent executes its share of a pairwise constraint.
To address this gap, we introduce a two-layer architecture combining fault detection and reconfiguration with a closed-form control barrier function safety filter. The central idea is to exploit the mutual constraints imposed by neighboring agents that implement the same filter. Under stated assumptions, this structure yields a quantitative lower bound on inter-agent separation under multiplicative actuator faults, without requiring fault identification or communication of nominal control inputs, and without relying on the actuator saturation limit. Because the guarantee does not depend on the nominal control law, it is preserved under the discontinuous controller switching caused by leader replacement.
Simulations and indoor flight experiments illustrate the benefits and limitations of the approach. We conclude by discussing how detection, reconfiguration, and safety filtering can work together to support dependable cooperation in autonomous multi-agent systems.
About Speaker
Toru Namerikawa received his Ph.D. degree in Electrical and Computer Engineering from Kanazawa University, Japan, in 1997. In 2009, he joined Keio University, Japan, where he is currently a Professor in the Department of System Design Engineering and the Director of the School of Integrated Design Engineering, Graduate School of Science and Technology. He has held visiting positions at ETH Zurich in 1998, the University of California, Santa Barbara in 2001–2002, the University of Stuttgart in 2008, and Lund University in 2010. He currently serves as an Associate Editor for IEEE Transactions on Control Systems Technology and IET Control Theory & Applications, Co-Editor-in-Chief of the IFAC journal Mechatronics, and an Editorial Board Member of IEEE Access. His main research interests include distributed and cooperative control, game theory, and their applications to cyber-physical systems. He received the 2014 Pioneer Technology Award from the SICE Control Division and the 2017 Outstanding Paper Award from SICE.